RVC P2600High Precision | Interference Resistant | Fast Imaging

1.6 MP binocular imaging across an 800-1200 mm working distance, providing contour, surface-shape, and 3D pose data for sole grinding, adhesive spraying, machine tending, and component positioning.
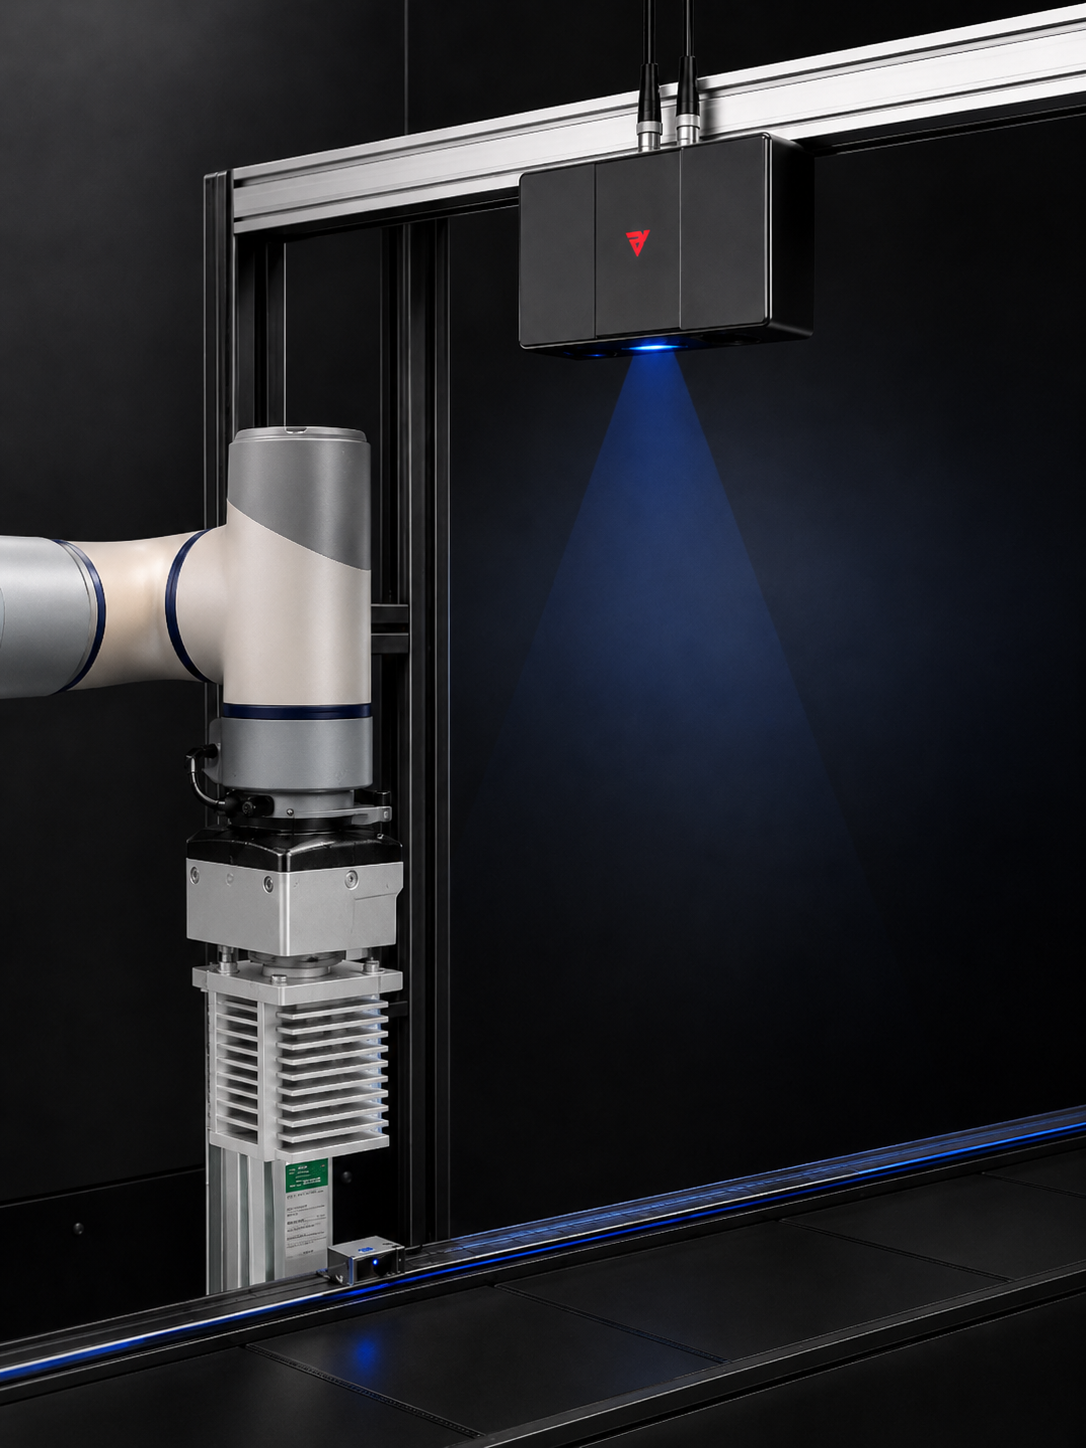
RVC-P2600 performing 3D scanning at a robotic guidance station
Robot equipment for automated sole grinding
01 / Key Challenges

Flexible Shoe Sole Grinding

Complex sole contours and curved surfaces, combined with variations in shoe size and part orientation, make fixed grinding paths prone to under-grinding, over-grinding, and path deviation.
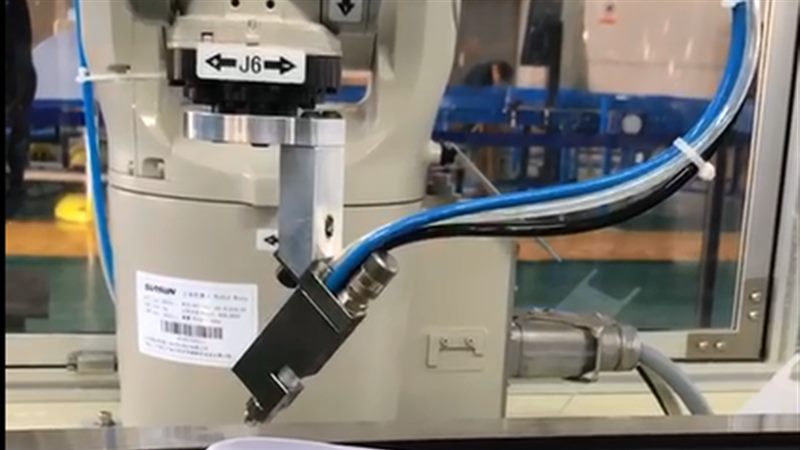
Robot spraying adhesive along a sole contour
02 / Key Challenges

Sole Adhesive Spraying Guidance

Variations in shoe type, size, and part placement can cause predefined spray paths to deviate from the actual sole edge. Curved surfaces also require the tool path to adapt to the actual surface geometry.
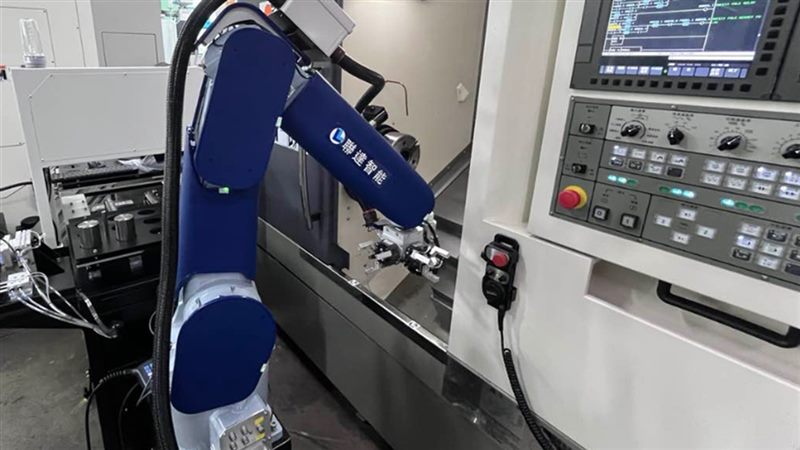
Vision-guided robot tending a machine tool
03 / Key Challenges

Flexible Machine Tending

Changes in part position and orientation on pallets and loading stations make fixed-coordinate systems highly dependent on precise fixturing. Frequent product changeovers can also require extensive robot teaching and adjustment.
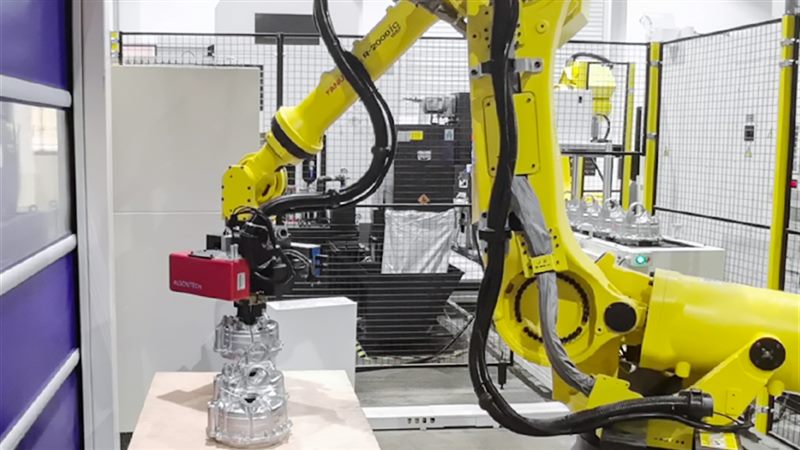
3D vision guiding a robot to locate metal components
04 / Key Challenges

3D Component Localization

Variations in part position, orientation, and model can directly affect picking and assembly. Unreliable localization data can propagate positioning errors into subsequent robot movements.
Product Features

Sole image and 3D point-cloud result
Typical Point Cloud Examples/ Shoe Sole Grinding
Shoe image and 3D point-cloud result
Typical Point Cloud Examples/ Shoe Adhesive Spraying
Machine tending scene and 3D point-cloud result
Typical Point Cloud Examples/ Machine Tending
Component positioning scene and 3D point-cloud result
Typical Point Cloud Examples/ 3D Component Localization & Measurement

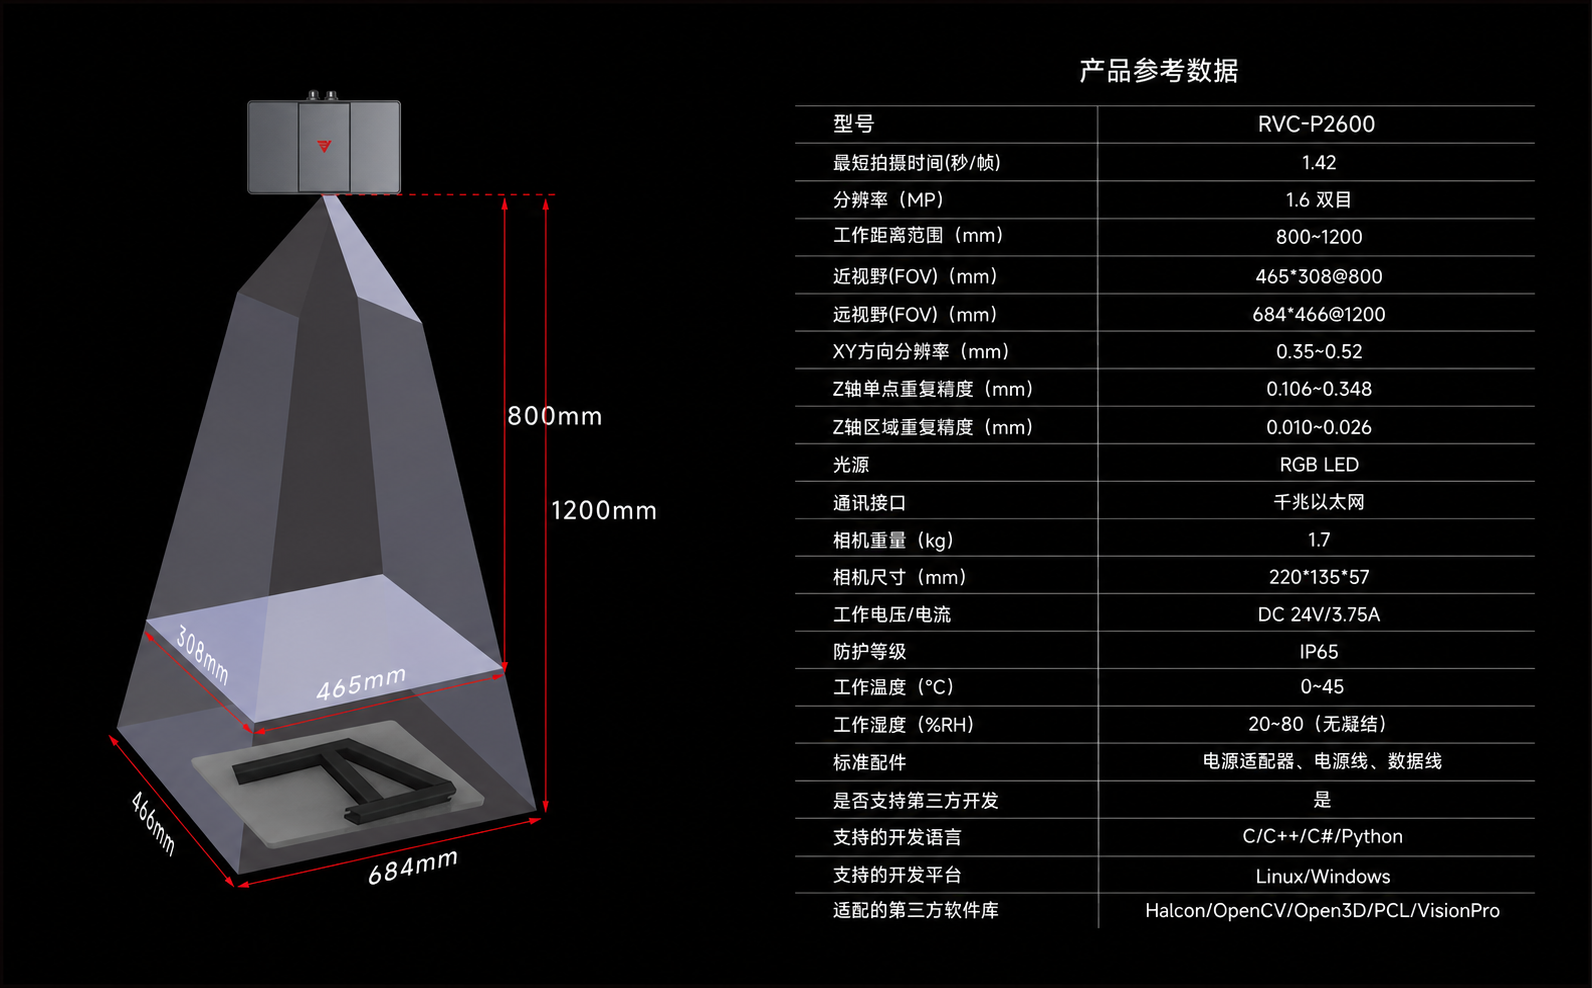
800-1200 mm Mid-Range Coverage

With a field of view ranging from 465 × 308 mm to 684 × 466 mm, the system covers the shoe sole and surrounding positioning area, providing 3D data for curved-surface path guidance.

1.42 s Single-Shot 3D Acquisition

Captures the sole contour and spatial pose before robot operation, providing input for spray start points, path planning, and curved-surface following.

1.6 MP Binocular 3D Imaging

Covers typical robot loading and unloading areas, while the compact 220 × 135 × 57 mm housing enables easy integration into machine-tool workstations.

0.35-0.52 mm XY Resolution

Combined with 0.010–0.026 mm regional repeatability, the system provides consistent data for component contour extraction and repeatable localization.
Typical Applications

Shoe Sole Grinding

Shoe Sole Adhesive Spraying

Machine Tending

Component Localization

Flexible Changeover Guidance

Curved-Surface Path Guidance

Robot 3D Guidance

Robot Picking Guidance

Product Specifications

RVC-P2600 working distance and field of view diagram
ParameterRVC-P2600
Resolution1.6 MP, binocular
Minimum Capture Time1.42 s / frame
Working Distance Range800-1200 mm
Near FOV465×308 mm @ 800 mm
Far FOV684×466 mm @ 1200 mm
XY Resolution0.35-0.52 mm
Z Single-Point Repeatability0.106-0.348 mm
Z Area Repeatability0.010-0.026 mm
Light SourceRGB LED
Communication InterfaceGigabit Ethernet
Camera Weight1.7 kg
Camera Dimensions220×135×57 mm
Operating Voltage / CurrentDC 24V / 3.75A
Ingress ProtectionIP65
Operating Temperature0-45℃
Operating Humidity20%-80% RH, non-condensing
Standard AccessoriesPower adapter, power cable, data cable
Third-Party DevelopmentYes
Supported LanguagesC / C++ / C# / Python
Supported PlatformsLinux / Windows
Compatible LibrariesHalcon / OpenCV / Open3D / PCL / VisionPro