RVC M2600C Built for Precision Segmentation and Picking
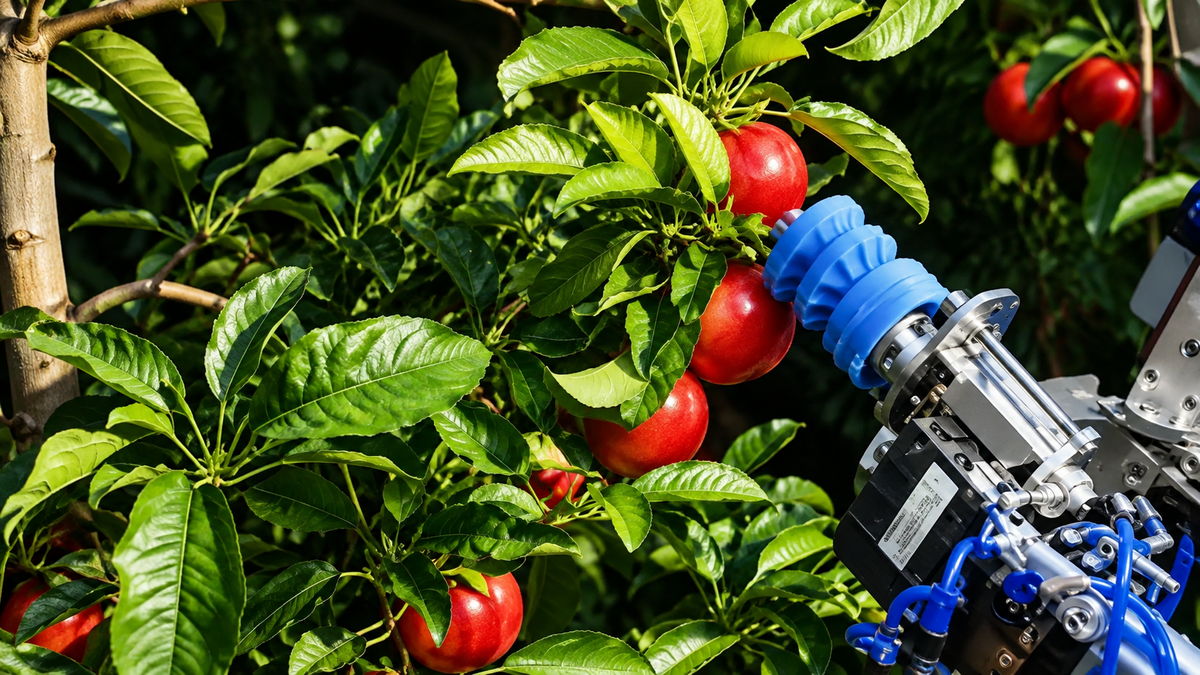
1440×1080 binocular color imaging captures color, texture, and 3D spatial information together. Optimized for highly reflective, multi-reflective, and black light-absorbing surfaces, it supports instance segmentation, precision picking, agricultural harvesting, and object detection.
Product Features
Built for Precision Segmentation and Picking High-Resolution Color Imaging
With 1440 × 1080 binocular color imaging, the system captures color, texture, and 3D spatial information simultaneously, providing richer visual features for object detection and instance segmentation.
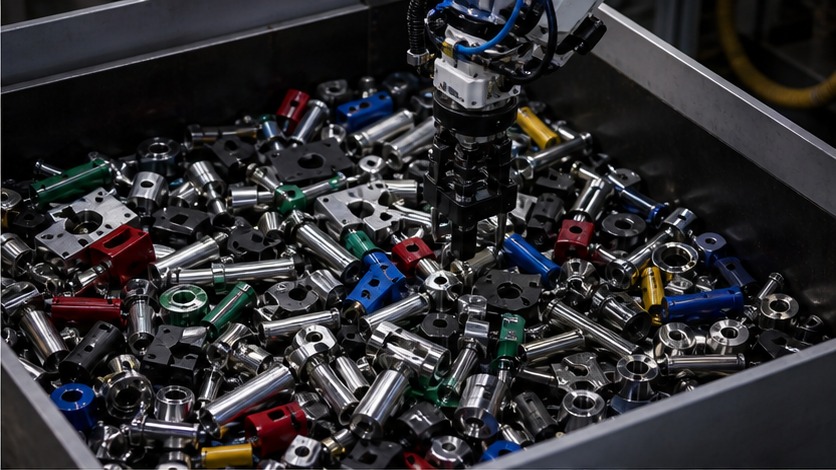
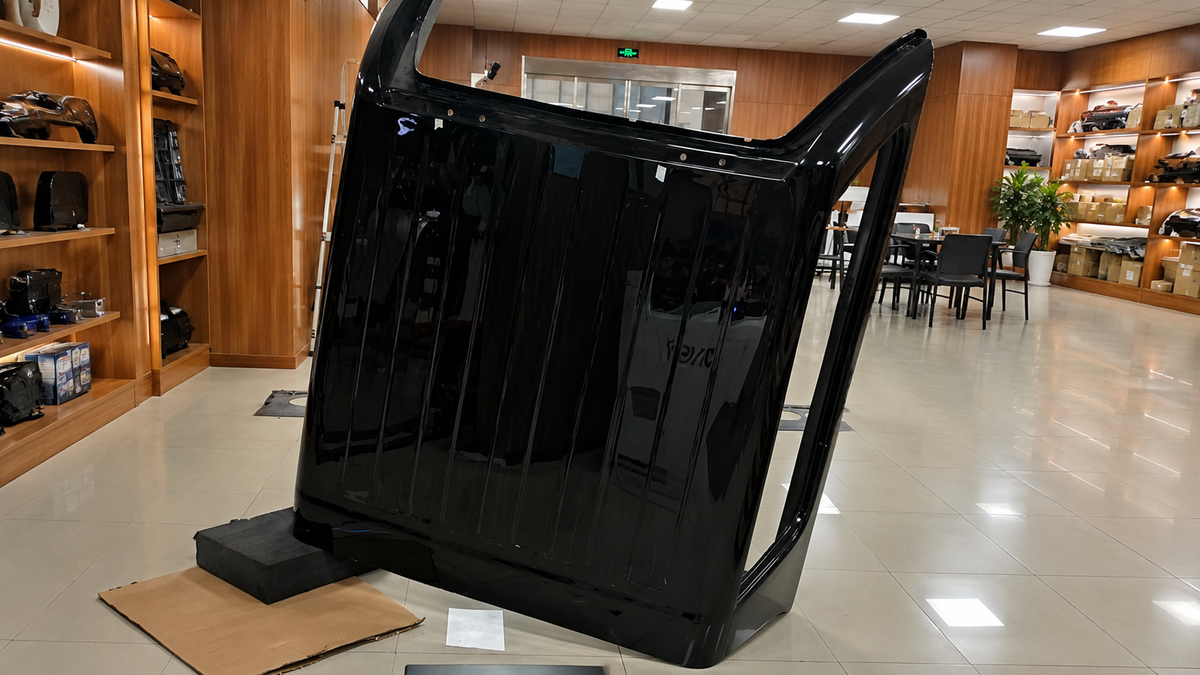
Highly Reflective Workpieces Fine Point Clouds
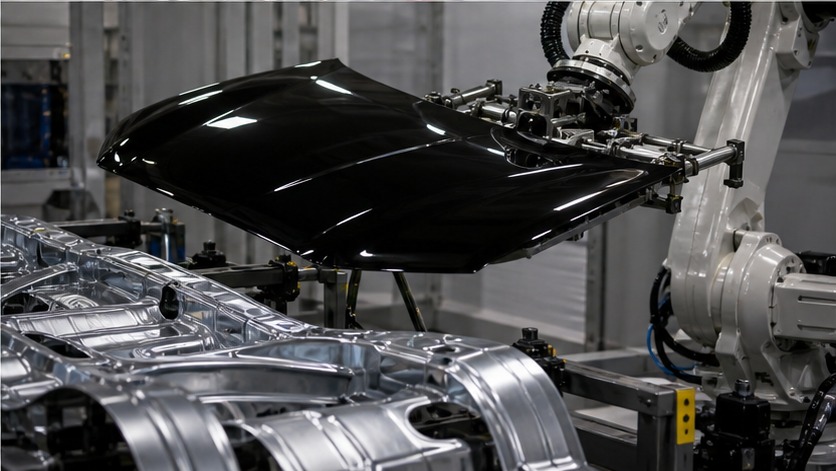
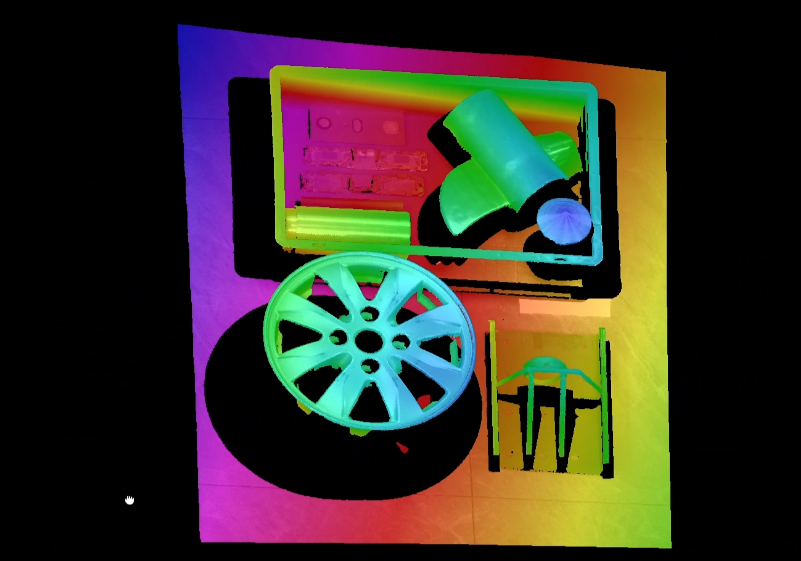
The multi-reflection suppression algorithm minimizes interference from complex reflective surfaces, improving point-cloud completeness and accuracy around grooves, sharp edges, and complex geometries.
Dark and Light-Absorbing Surfaces Robust 3D Imaging
Optimized for black, light-absorbing surfaces, localized reflections, and multiple-reflection conditions, the 3D imaging system delivers more complete point clouds on dark-colored parts and complex material surfaces.
Line-Scan Mode with High Ambient-Light Resistance >60 0,000 Lux
Supporting natural daylight, semi-outdoor environments, and high-intensity ambient lighting, the system delivers stable and reliable 3D imaging for agricultural harvesting and open workstation applications.
Typical Applications
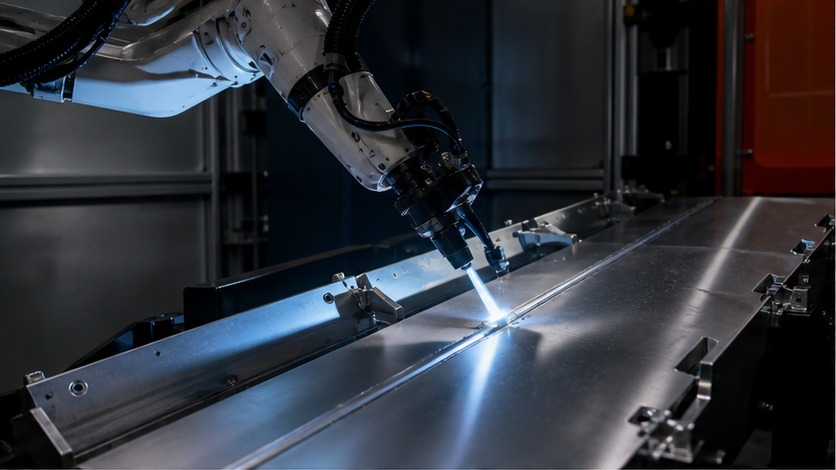
Weld Seam Detection
Part Segmentation
Random Bin Picking
Color-Based Classification
Agricultural Harvesting
Object Detection
Defect Detection
3D Localization
Product Specifications
| Category | Parameter Item | RVC-M2600C |
|---|---|---|
| Basic Data | Camera Dimensions | 170 × 73.5 × 73 mm |
| Camera Weight | 1.2 kg | |
| Camera Resolution | 1440 × 1080 (1.6 MP), binocular, color | |
| Light Source | Laser | |
| Data Interface | Gigabit Ethernet | |
| Operating Voltage / Current | DC 24V / 2A | |
| SDK Supported Systems | Linux / Windows | |
| SDK Supported Languages | C / C++ / C# / Python | |
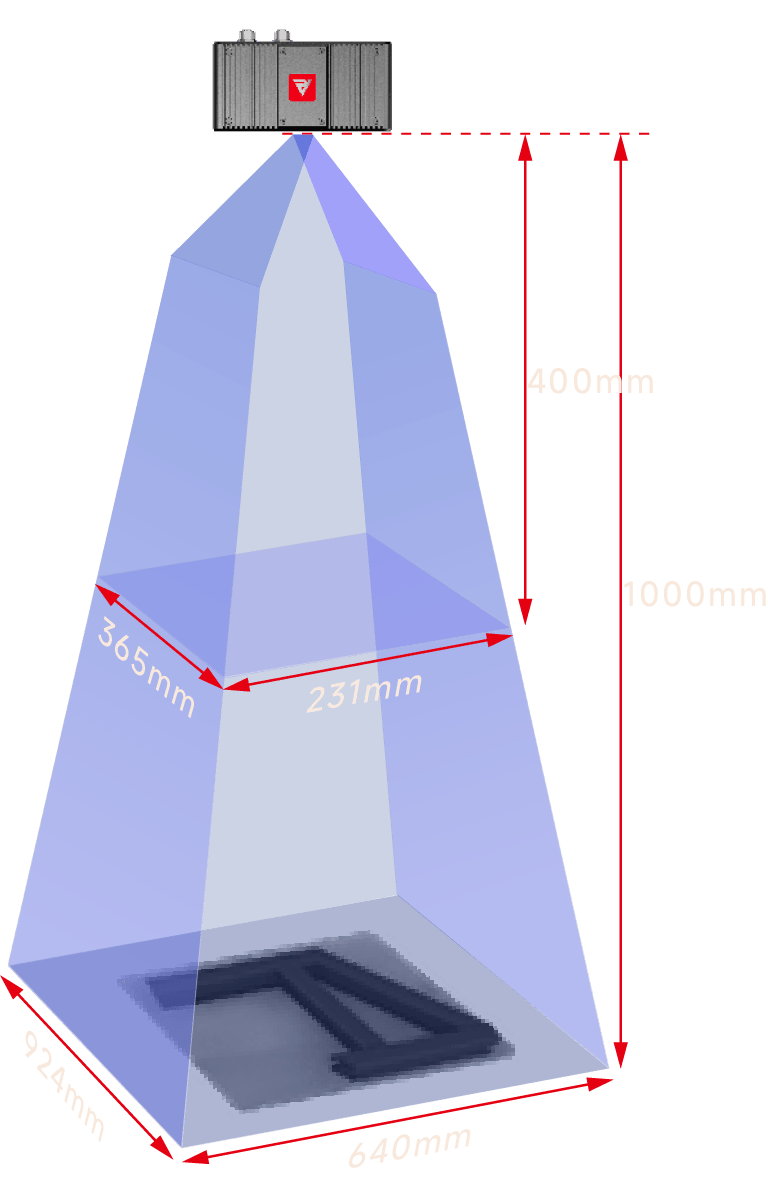
| Performance | Working Distance | 400–1000 mm |
| Near FOV | 365 × 231 mm @ 400 mm | |
| FOV at Optimal Working Distance | 600 × 450 mm @ 700 mm | |
| Far FOV | 924 × 640 mm @ 1000 mm | |
| Z-Axis Single-Point Repeatability | 0.04 mm @ 1000 mm | |
| Z Area Repeatability | 0.02 mm @ 1000 mm | |
| XYZ Spatial Measurement Error | 0.27–0.66 mm;full FOV <0.2%;FOV center <0.1% | |
| Capture Time | 1.1–2.3 s / frame | |
| Measurement Notes | Performance values tested at a normal room temperature of 26℃ | |
| Stability | Housing Protection | IP65 Ingress Protection |
| Ambient-Light Resistance | Line-scan mode >600,000 Lux | |
| Operating Temperature | -20–50℃ |